If you have ever dimmed an LED with Arduino code, adjusted a motor’s speed without a physical rheostat, or wondered how a solar charge controller manages to charge a battery smoothly without wasting energy as heat, you have encountered pulse width modulation, commonly known as PWM.
It is one of the most widely used techniques in electronics for controlling power delivery efficiently.
This article explains what PWM is, how it works, and where it turns up across student projects and real Nigerian applications.
What Pulse Width Modulation Actually Is
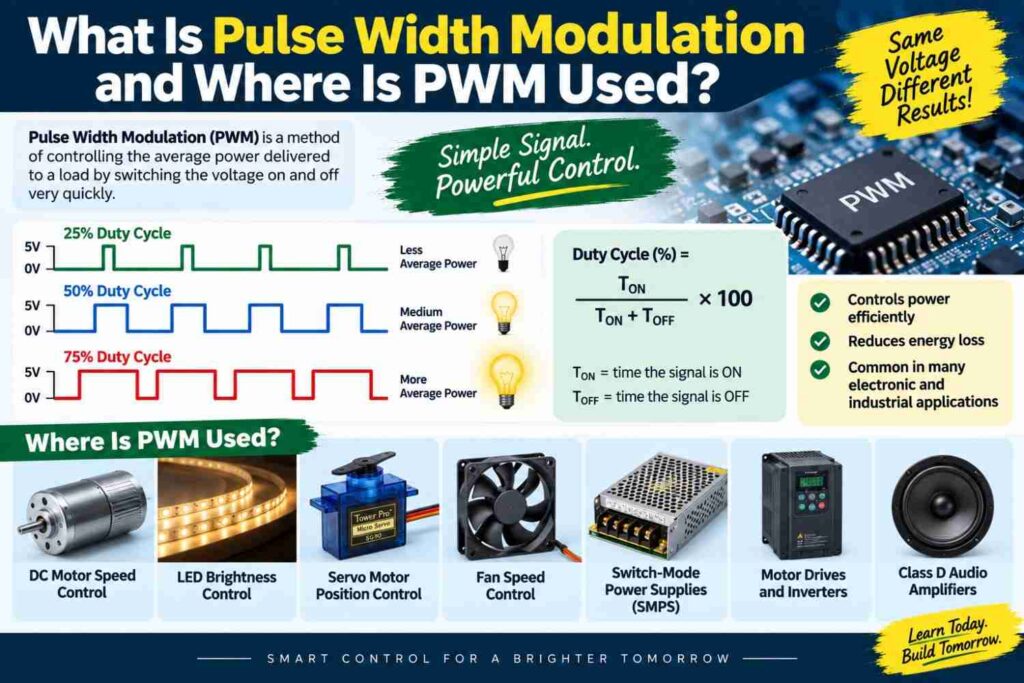
Pulse width modulation is a technique for controlling the average power delivered to a load by rapidly switching a digital signal on and off and varying the proportion of time it spends on versus off.
Instead of producing a steady, reduced voltage the way a resistor or rheostat would, PWM keeps the signal at full voltage during the “on” portion and zero during the “off” portion, switching between the two so quickly that the connected device responds to the average effect rather than each individual pulse.
This makes PWM a fundamentally digital technique that produces an analog-like effect, a relationship explored further in our analog versus digital signals article.
Understanding Duty Cycle
The key concept in PWM is duty cycle, which is the percentage of time the signal spends in the “on” state during each cycle. A duty cycle of 100 percent means the signal is always on, delivering full power. A duty cycle of 50 percent means the signal is on for half of each cycle and off for the other half, delivering roughly half the average power.
A duty cycle of 0 percent means the signal is always off. By adjusting the duty cycle, you can smoothly control everything from an LED’s brightness to a DC motor’s speed to the amount of charge current flowing into a battery.
How PWM Signals Are Generated
Most microcontrollers, including the ATmega328 used in Arduino boards, have dedicated hardware timers capable of generating PWM signals on specific pins without requiring the processor to manually toggle the pin in software. This hardware-based generation keeps the switching frequency stable and frees up processing time for other tasks.
A typical Arduino PWM pin can be set to any duty cycle value using a single line of code, and the underlying timer hardware handles the precise, rapid switching automatically in the background.
Common Applications of PWM
PWM shows up across an enormous range of electronic systems because it is an efficient way to control power without wasting energy as heat, which is the major drawback of older resistive control methods.
| Application | What PWM Controls | Why PWM Is Used |
|---|---|---|
| LED dimming | Average brightness | Smooth control without extra heat loss |
| DC motor speed control | Average motor speed | Efficient, precise speed adjustment |
| Solar charge controllers | Battery charging current | Regulates charge without wasting solar energy |
| Generator AVR systems | Excitation current | Fine control of output voltage regulation |
| Servo motor positioning | Shaft angle | Pulse width directly maps to position |
| Audio signal generation | Approximated waveform | Digital circuits can produce analog-like sound |
PWM in Solar Charge Controllers
This is a particularly relevant example for Nigerian students and hobbyists, given how common solar power setups have become as a response to unreliable grid supply.
A PWM-based solar charge controller regulates the flow of current from the solar panel into the battery by rapidly switching the connection on and off, tapering the duty cycle down as the battery approaches full charge to avoid overcharging.
This is different from the more advanced MPPT approach, which is discussed in greater depth in our solar charge controllers article, but both rely on the same underlying principle of controlling average power delivery rather than dissipating excess energy as wasted heat.
Setting Up a Basic PWM Experiment
A simple hands-on experiment is one of the best ways to understand PWM intuitively rather than just theoretically.
- Connect an LED with a current-limiting resistor to a PWM-capable pin on a microcontroller board such as Arduino.
- Write a short program that gradually increases the duty cycle from 0 to 100 percent and observe the LED brightness change smoothly.
- Replace the LED with a small DC motor and a suitable driver circuit, then observe how duty cycle changes affect motor speed.
- Use an oscilloscope, if available in your lab, to actually view the switching waveform and confirm the duty cycle matches what the code specifies.
- Note the switching frequency used and consider why a frequency that is too low might cause visible flicker in an LED or audible whine in a motor.
Choosing an Appropriate PWM Frequency
Frequency matters just as much as duty cycle. If the switching frequency is too low, an LED may visibly flicker, or a motor may run roughly and produce an audible hum. If the frequency is too high, switching losses in the driving transistor can increase and reduce overall efficiency.
Most practical PWM applications use frequencies ranging from a few hundred hertz up to tens of kilohertz, chosen based on the specific load being controlled, and datasheets for motor drivers and LED controllers typically recommend a suitable range.
Common Misconceptions
- “PWM produces a true analog voltage.” PWM is a digital signal switching fully on and off; it only behaves like a reduced analog voltage after the connected device or a filter averages the rapid pulses.
- “Higher PWM frequency is always better.” Excessively high frequencies can increase switching losses in driver circuits, so the ideal frequency depends on the specific application and load.
- “PWM wastes energy just like a resistor-based control method.” PWM is efficient because the switching device is either fully on or fully off, minimizing power dissipated as heat compared to resistive control methods.
Frequently Asked Questions
What is the difference between PWM and a true analog output?
PWM switches rapidly between fully on and fully off states to create an average effect, while a true analog output produces a continuously varying voltage directly, typically requiring a digital-to-analog converter.
Can PWM be used to control AC loads?
PWM is most commonly used with DC loads, though related switching techniques are used in AC motor drives and inverters, which involve additional circuitry beyond basic PWM.
Why do servo motors use a specific PWM pulse width rather than duty cycle?
Standard hobby servo motors interpret the actual pulse width, typically between about 1 and 2 milliseconds, as a direct position command, which is a specialized use of PWM timing rather than average power control.
Final Thoughts
Pulse width modulation is a simple idea with an outsized impact on modern electronics: by switching a signal on and off rapidly and adjusting the proportion of time spent in each state, PWM delivers efficient, precise control over motors, lights, and power systems.
Its relevance stretches from a beginner’s first LED dimming project to sophisticated solar charge controllers and generator voltage regulators used across Nigeria. Understanding duty cycle, frequency, and how PWM bridges the digital and analog worlds gives you a technique you will use again and again in embedded systems and power electronics work.